Natural-language task planning is attractive because it can reduce detailed programming for variable work. It also creates a timing and authority problem if a probabilistic plan is allowed to flow directly into motion.
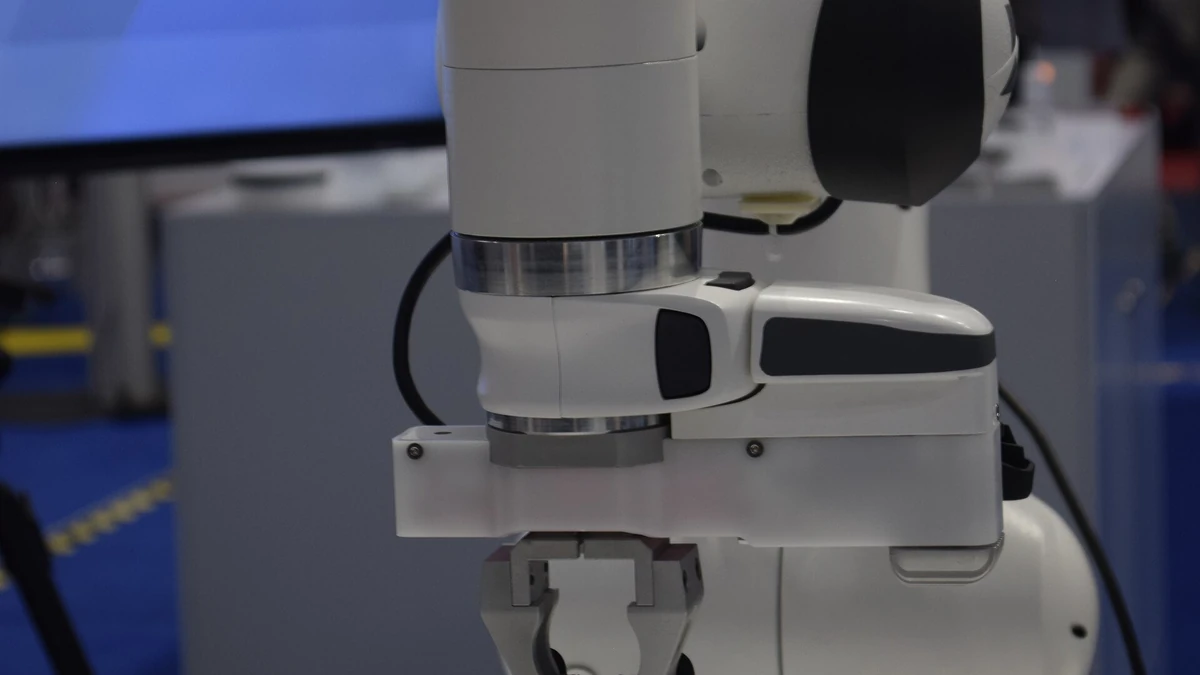

Yaskawa’s official integration announcement gives the two sides different jobs: Gemini Robotics-ER 1.6 decides what should happen, while MOTOMAN NEXT handles how the robot perceives, plans a path, uses force, and executes. That is a development architecture, not a priced general-purpose package with published factory reliability.
Choose the control boundary before choosing the model
The practical choice is not Gemini versus an industrial robot. It is how far a high-level model may decompose a goal before a deterministic controller validates state, coordinates, limits, and permissions. A request such as ‘sort these parts’ can be ambiguous; motor current, joint speed, protected space, and emergency-stop state cannot be. The high-level plan therefore needs an expiry time and a controller-side right to reject stale or infeasible goals. High-level reasoning and servo control operate on different clocks.
Where high-level embodied reasoning fits
Google DeepMind describes Gemini Robotics-ER 1.6 as a model for spatial reasoning, task planning, success detection, and tool use. In a Yaskawa cell, the allowed tools and data paths still need to be named. A model-level ability to call a tool does not prove that open web search, file access, or every external service is active. Production integration should whitelist vision queries, approved recipes, and bounded recovery commands. Model capability must be narrowed to the tools allowed in the actual cell.
What must remain in the robot and cell layers
Yaskawa identifies machine vision, path planning, and force sensing as MOTOMAN NEXT capabilities. Vision-to-robot calibration, tool-center-point definition, force-sensor zeroing, collision checking, and independent safety logic remain physical responsibilities. The release describes recognizing a dropped object and retrying, but a drop, misclassification, no-path result, force exceedance, and protective stop should have different retry counts and escalation owners. A recovery demonstration cannot stand in for every fault class.
Compare the options by failure consequence
A flexible planner may fit a cell with frequent product and layout changes where conventional teaching dominates engineering time. A validated fixed sequence remains the stronger option when cycle determinism and a narrow operating envelope matter more than semantic flexibility. The robot VLA evaluation guide helps separate average task success from latency tails, generalization, safety evidence, and the labor needed to supervise failures. Flexibility has value only when its validation and supervision cost is counted.
| Decision area | Gemini Robotics-ER 1.6 role | MOTOMAN NEXT or cell role | Unknown to verify |
|---|---|---|---|
| Task goal | Interpret intent and propose steps | Check execution feasibility | Supported commands and prohibited work |
| Scene | Reason about objects and success | Measure precise pose and geometry | Occlusion and calibration error |
| Motion | Select the next step | Plan path, speed, and joints | Worst-case latency and timeout |
| Contact | Interpret intended result | Measure force and grip state | Force limits and sensor failure |
| Recovery | Replan a sequence | Stop and execute permitted retry | Escalation, logs, and rollback |
Route the demonstration through a factory acceptance test
Start with a fixed reference task and compare conventional teaching with the agentic route under the same objects, coordinates, and safety limits. Then vary position, lighting, object identity, and instruction across 10 to 20 combinations. Inject stale scenes, calibration offsets, dropped parts, unreachable paths, timeouts, and force-limit events. Count safe refusal, correct stop, human escalation, wrong retry, recovery time, and rollback—not only completion. Availability, regional support, controller versions, and pricing were not announced.
- model latency
- controller latency
- audit logs
- MES permissions
- model rollback
Questions readers ask next
Which decisions belong to Gemini Robotics-ER 1.6, and which must remain with MOTOMAN NEXT and the cell’s independent safety controls?
No cost figure or programming-time reduction was published. Detailed teaching may fall for variable work, but model use, integration, validation, fault analysis, safety approval, and support add new costs. Compare total engineering and operating labor on the same task.
How should a factory test stale goals, coordinate-frame errors, dropped objects and bounded retries before treating the demonstration as deployable?
The announcement does not publish a commercial responsibility matrix. A contract should divide model output, Yaskawa services, system integration, cell safety, software updates, and rollback ownership. Otherwise each supplier can point to another layer when the cell fails.
Official source trail: