A specimen’s automation path begins with identity, not motion: scan the code, verify the order, assign a destination, move the carrier, hand it to an instrument, and write the physical result back to the laboratory information system. ABB and Roche’s official collaboration announcement targets that chain through pathology-slide handling and core-lab specimen and material logistics.

Trace the announced system boundary
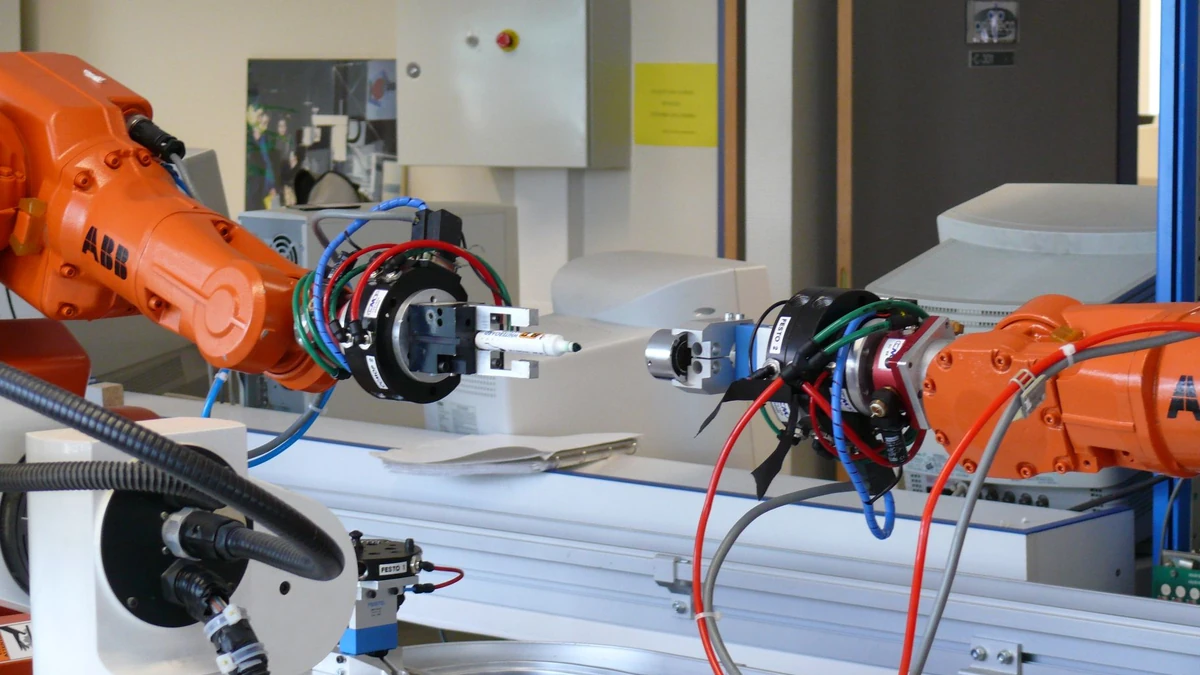
ABB and Roche say they will develop and commercialize laboratory robotics using articulated robots and autonomous mobile manipulators. They name two initial workflows; they do not publish a hospital deployment, regulatory clearance, throughput gain, contamination reduction, or patient outcome. Treat the statement as a development scope and supplier relationship, not a completed clinical installation. The announcement names development targets, not measured hospital outcomes.
Make specimen identity the first sensor interface
A camera can find a tube while the system still has the wrong patient, order, container, cap state, orientation, priority, or instrument destination. Barcode and order matching should block motion when identity is uncertain. Roche’s diagnostics-automation page also distinguishes physical transport, workflow orchestration, and data analysis, reinforcing that mechanical and information interfaces must agree. Visual recognition cannot compensate for broken chain of custody.
Let AI suggest priority without erasing the rule trail
A model may route around a busy analyzer or propose a queue based on incoming volume. Any change to a clinical priority needs the governing rule, reason, approver, and version in the log. If the model times out or reports uncertainty, the workflow needs a known laboratory rule to fall back to. An urgent label cannot authorize the robot to bypass instrument readiness or safety interlocks. Priority logic must remain auditable and reversible.
| Workflow stage | Timing basis | Timeout state |
|---|---|---|
| Receive and identify | Barcode and order agreement | Quarantine for human review |
| Dispatch | Priority, queue, route, and instrument wait | Use approved rule or hold |
| Pick | Container stability and grip | Return to safe location; bounded retry |
| Handoff | Instrument-ready and door state | Prohibit release |
| Record | LIS ID matches physical location | Block the next step and alert |
Separate mobile-base control from arm control
A fixed arm suits repeated handling at a defined bench. A mobile manipulator navigates between instruments and then places a sample. The base needs people and obstacle protection; the arm needs contact, speed, and force limits. Their stop zones and controllers should be verified independently even though an orchestration layer sees one task. The AMR operations guide helps separate flexible routing from safe physical execution. A mobile manipulator combines two hazard envelopes without making them one controller.
Validate the release, not only the grasp
Placement can be harder than pickup because rack tolerances, instrument ports, attached slides, tilted tubes, and incomplete caps change the release state. Cross-check vision, weight, and force rather than trusting one signal. Cleanability also depends on contact material, chemistry, schedule, spill isolation, consumables, and cross-contamination testing under the laboratory’s quality system and jurisdiction-specific requirements. A clean handoff needs evidence that the destination accepted the correct specimen.
Join robot and specimen telemetry on one timeline
The event log should bind robot position, task ID, specimen ID, grip force, handoff time, retry, human intervention, cleaning state, dwell condition, and instrument acknowledgment. If an outage leaves a tube physically on a transfer surface while the LIS records it inside an analyzer, the automation has increased speed at the expense of custody. Temperature, light protection, and maximum dwell time belong to the same record.
Automation telemetry has value only when it reconstructs the specimen’s physical state.
| Capacity area | Sizing unit | Function to protect under overload |
|---|---|---|
| Specimens | Hourly volume and peak arrival | Identity and urgent handling |
| Robot fleet | Concurrent tasks, charging, and maintenance | Safe stop and manual aisle |
| Vision and AI | Cameras, frames, and tail latency | Uncertainty alert and fallback |
| LIS | Messages, retries, and duplicates | ID integrity and audit log |
| Power and network | UPS, dead zones, and recovery | Known specimen location |
Use exception injection as the first integration test
A useful pilot creates barcode mismatch, tilted containers, a closed instrument door, network loss, an urgent specimen, a spill, a stopped mobile base, and a manual recovery. Compare the entire specimen dwell time and error detectability with the human baseline. Success means identity, custody, contamination control, and recovery are no worse—not merely that the robot moved many normal samples.
Normal throughput is a weak test of an exception-heavy clinical workflow.
- version rollback
- peak-hour load
- error detection
- specimen ID
- order ID
Questions readers ask next
Why do pathology-slide handling and core-lab intralogistics come before diagnostic decision-making in the announced collaboration?
No universal interface list was published. Confirm each instrument, LIS message, specimen identifier, readiness signal, and error code. Robot motion is only one part of integration; the digital handoff must be validated device by device.
How should a lab test chain of custody, dwell conditions, contamination controls and digital-to-physical handoffs across robots and the LIS?
First reconcile the physical specimen ID with the digital task ID. Then align the last sensor read, robot handoff, instrument-ready signal, and any manual intervention by timestamp. Restore identity and location before interpreting an AI routing decision.
Official source trail: