Skip to content

Physical AI Lab

  • Home
  • Physical AI
  • VLA Models
  • Sim-to-Real
  • Foundation Models
  • Humanoid Robots
  • 한국어
  • 日本語
  • 简体中文
  • 繁體中文

Physical AI Lab

Sim-to-Real Transfer in Robotics: How Policies Cross the Reality Gap
Published: July 28, 2026 · Updated: October 12, 2026 by Physical AI Lab
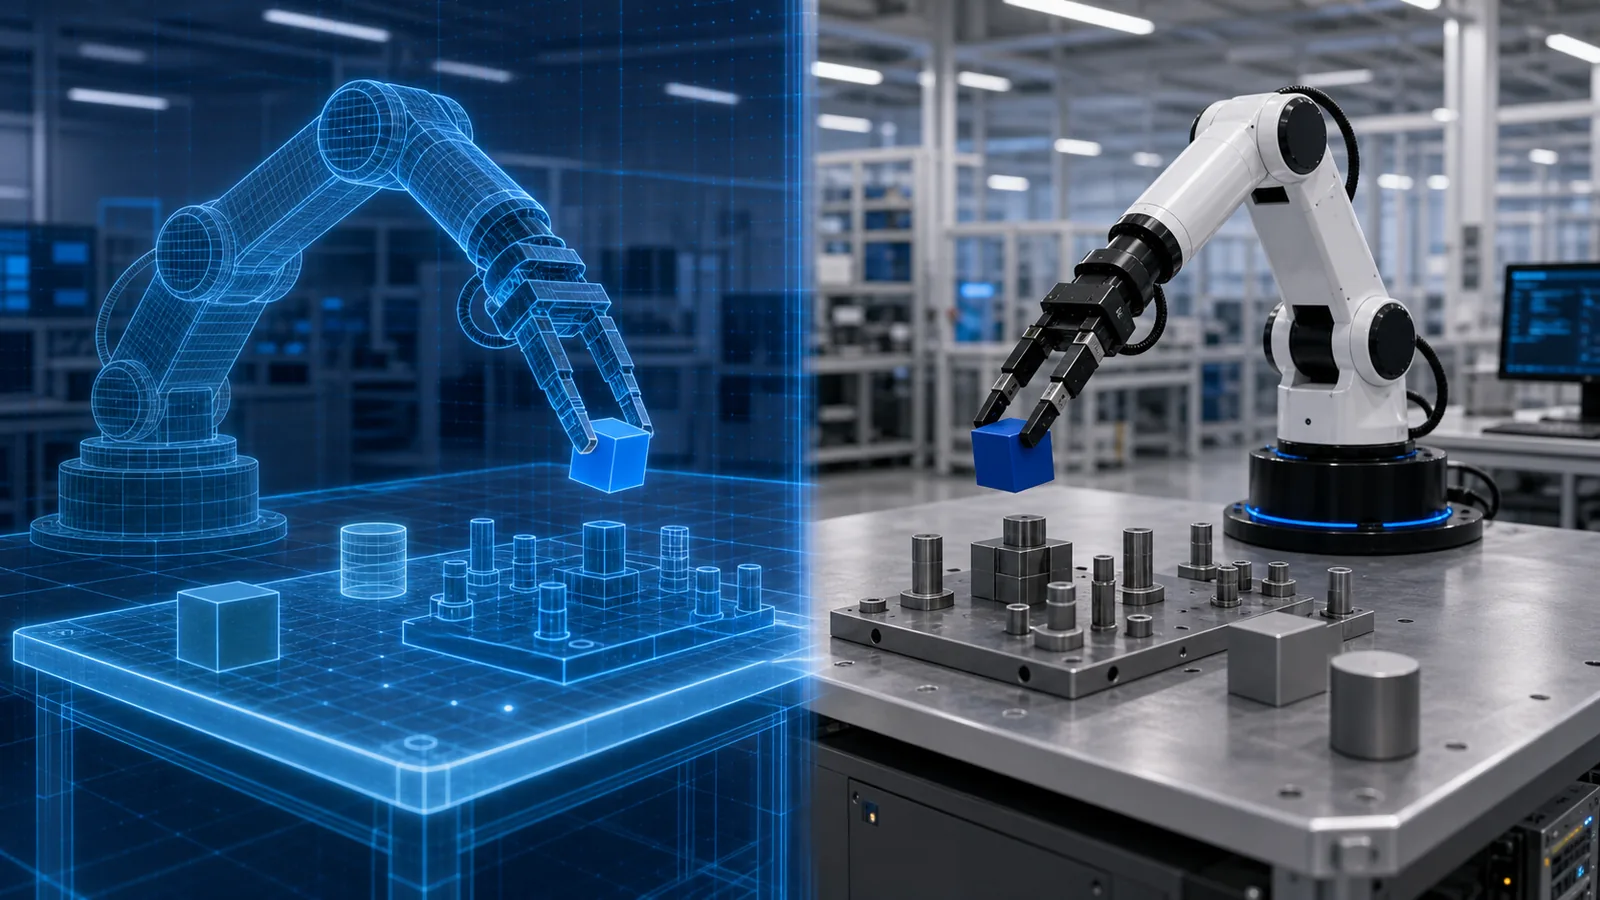
Robot policy moving from a simulated environment to a physical robot

A practical guide to sim-to-real robotics: reality-gap causes, domain randomization, system identification, transfer methods and real-world validation.

Categories World Models and Simulation

What Is Physical AI? A Practical Guide to AI That Acts in the Real World

Published: July 28, 2026 · Updated: August 1, 2026 by Physical AI Lab
Robotic hand interacting with physical objects in a real-world AI system

Learn what physical AI means, how perception, reasoning and robot control fit together, where it is used, and how to evaluate real systems.

Categories Physical AI Fundamentals
Newer posts
← Previous Page1 … Page49 Page50

Explore Physical AI

  • Physical AI Fundamentals
  • Vision-Language-Action Models
  • Sim-to-Real Transfer
  • Robot Foundation Models
  • Humanoid Robots

View all English articles

About This Site

Physical AI Lab publishes independent, source-linked guides to embodied AI, robotics and real-world deployment.

Read the Korean edition · 日本語版を読む · 简体中文版 · 繁體中文版

© 2026 Physical AI Lab · English Edition · 한국어 · 日本語 · 简体中文 · 繁體中文