A dock count and a flight count are not a reliability rate. Skydio’s milestone announcement says 1,070 Docks were deployed one year after the first production unit shipped and cites more than four million company-wide flights. It does not identify four million Dock flights or a fully autonomous share.
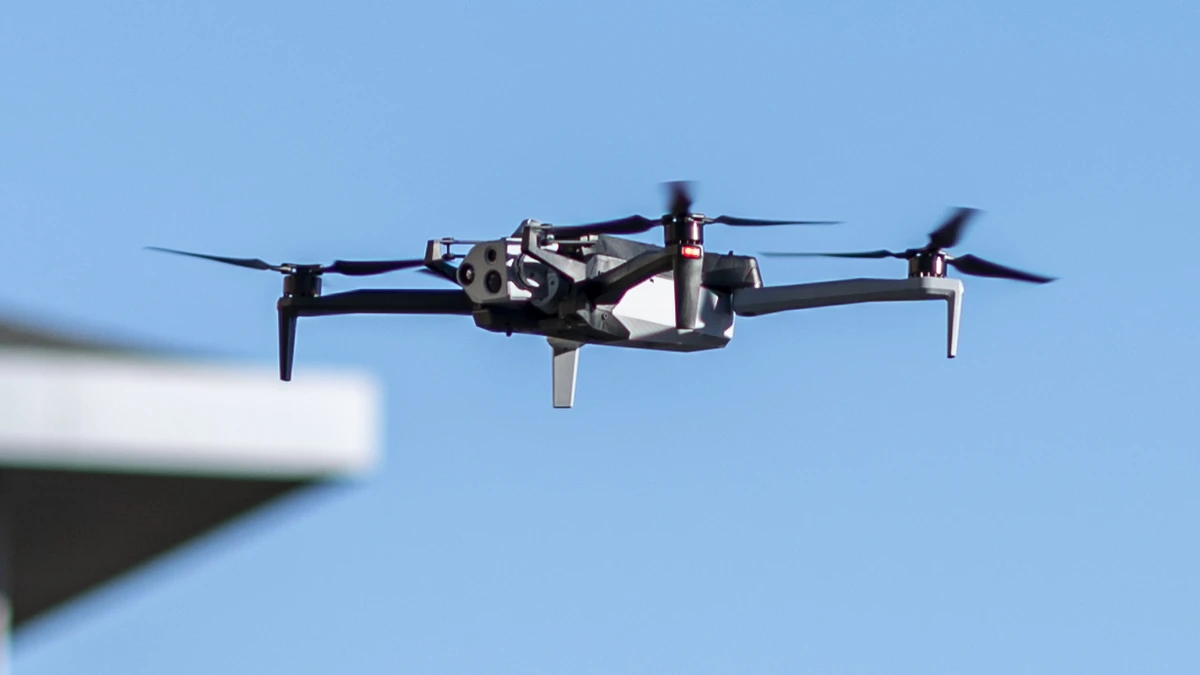

The common myth: a dock makes the operation unmanned
A dock can charge, protect, and launch an aircraft, but an operation still needs a healthy aircraft, mapped site, network and cloud path, authorized remote pilot or supervision model, weather limits, maintenance, and recovery. Dock installation alone does not create an unmanned organization. Even a scheduled launch can contain human approvals, remote interventions, or post-flight handling that the word autonomous hides. Hardware deployment and labor-free operation are different claims.
What the two milestone numbers actually cover
Skydio says 1,070 Docks were deployed across public safety, critical infrastructure, and defense programs in three countries. The more-than-four-million-flight figure is presented at company scale. The announcement does not disclose whether every Dock is the same model or active for the same period, how many flights came from Docks, or how many occurred without intervention. Do not divide one headline number by the other to create a fictional utilization rate. Company-scale cumulative flights and Dock utilization use different denominators.
Inputs and outputs still span four operating layers
Remote operations depend on the aircraft and payload, Dock health, cloud or console, and operating procedure. Inputs include mission plan, weather, airspace, site status, battery, communications, and authorization. Outputs include usable data, incident and intervention records, maintenance needs, and a known landing state. The Physical AI drone architecture shows how a strong perception stack can still fail at communications or recovery. A remote program is a system of systems.
Autonomy is a workflow, not one software switch
Autonomy can plan a route, avoid obstacles, launch, inspect, return, and dock. Each transition needs a timeout and owner. A mission that pauses for remote review is not necessarily a failure, but it should not be counted as equivalent to an unattended sortie if the metric is autonomy. Separate scheduled, operator-approved, remotely piloted, intervened, aborted, recovered, and completed missions. Supervision level belongs in the mission record.
Use cases show breadth, not average performance
Skydio cites missing-person searches, fire hotspots, power-line inspection, and military installation ISR. These examples establish a range of applications, not a common detection rate, response-time improvement, or cost saving. Each use case has its own sensor target, false-negative consequence, data chain, and regulatory context. A customer case should report mission denominator and baseline rather than only an anecdote. Examples establish existence, not representative performance.
Counterexample: a successful flight with a failed operation
Imagine an aircraft launches, flies its path, and lands in the Dock, yet the camera was misconfigured or the required asset was occluded. The flight is successful; the inspection is not. The reverse can also occur when valuable data is captured but a manual recovery is required. Operations reporting should retain both flight outcome and customer-task outcome so autonomy scale does not mask data quality.
Customer value can fail after the aircraft completes its route.
| Adjacent term | What it can mean | Required denominator |
|---|---|---|
| Deployed Dock | Installed or delivered at a site | Active site-months and availability |
| Flight | Any company-recorded sortie | Attempted, completed, aborted, and intervened |
| Autonomous | One or more automated phases | Supervision and intervention by phase |
| Mission success | Aircraft or customer task completed | Data quality and business outcome |
| Scale | Large cumulative count | Exposure-adjusted reliability and cost |
Learn from the missing denominators
The announcement does not provide customer-level uptime, mission completion, incident rate, intervention frequency, cancellation, recovery, or flights per aircraft. Absence is not evidence of poor performance, but it prevents a reliability conclusion. A real scale ledger needs active-site months, eligible missions, attempted missions, weather cancels, system cancels, human interventions, safety events, data-quality failures, and mean recovery time.
Reliability is a ratio that needs exposure and failure counts.
- customer baseline
- waiver condition
- pilot responsibility
- deployed Dock
- active Dock
Questions readers ask next
Do the reported totals distinguish installed docks, active sites, scheduled missions, remotely supervised flights and fully autonomous sorties?
It cannot establish the fully autonomous share, customer-level uptime, incident rate, task-quality rate, unit economics, or operator workload. Those questions need active exposure, attempted-mission, intervention, failure, and recovery denominators.
Official source trail: