The published WRC 2026 Tri-Co Robot Challenge design paired UAV reconnaissance with ground embodied-intelligence systems. The design is useful for examining shared coordinates, uncertainty and task handoffs; it says nothing about the competition result.
What the Tri-Co challenge confirms
Official information names teamwork between aerial reconnaissance and ground embodied intelligence as a competition area. The detailed sensor configuration and scoring rules must be checked in the competition rules, and the announcement does not mean every mission is fully autonomous.
Official rules and organizer statements define the scope of this review. Any price, lead time or mission success rate that is not published for the Tri-Co challenge remains unknown.
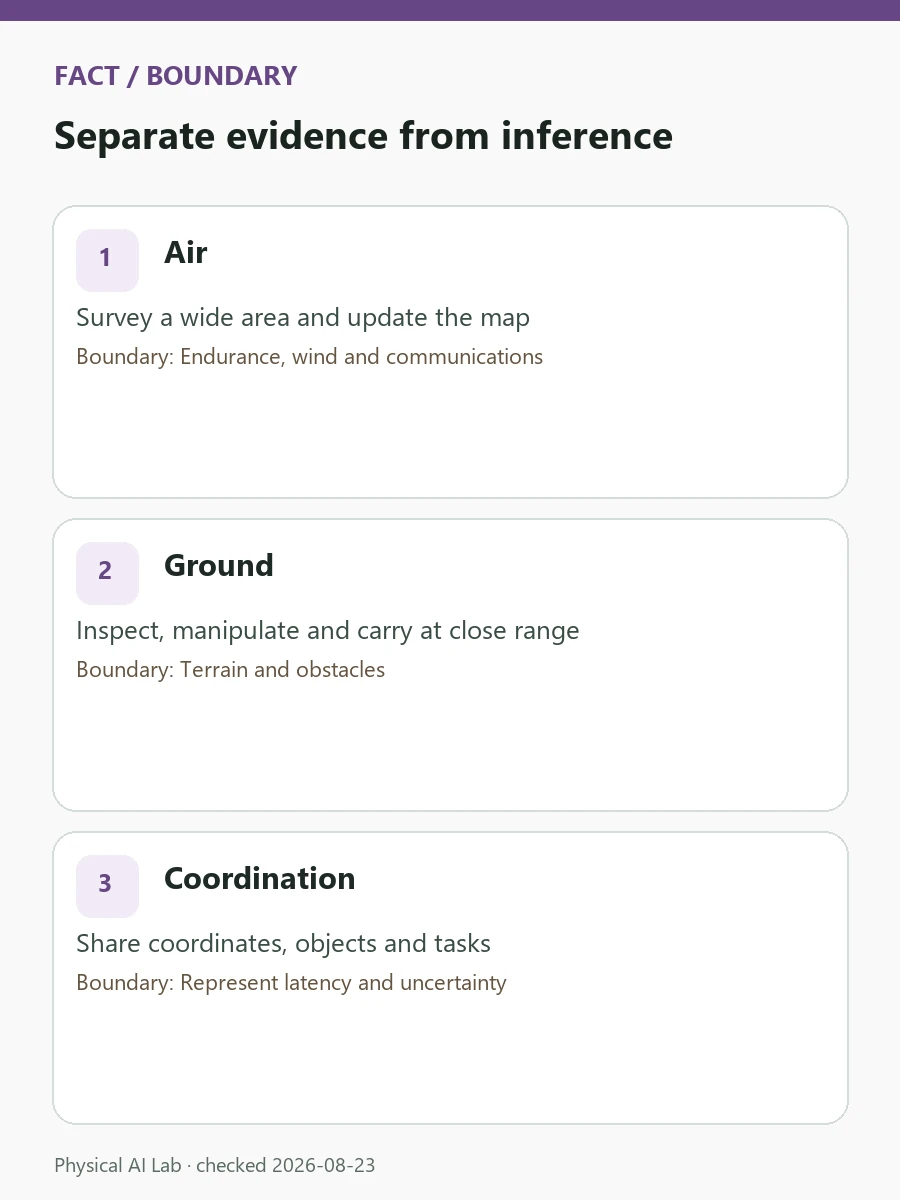
| Layer | Role in the mission | Operating constraint |
|---|---|---|
| Air | Survey a wide area and update the map | Endurance, wind and communications |
| Ground | Inspect, manipulate and carry at close range | Terrain and obstacles |
| Coordination | Share coordinates, objects and tasks | Represent latency and uncertainty |
Shared state matters more than shared video
The critical interface is a common coordinate frame, object state, uncertainty and mission priority—not simply a video stream. Each robot also needs a rule for stopping safely or switching to an independent task when communications fail.
Physical AI performance depends on sensor time synchronization, state estimation, planning, low-level control, safety limits and failure recovery operating as one continuous chain.
Test the handoff under failure, not only ideal conditions
Ask how often the same mission was repeated, when a person intervened and how long recovery took after a stop. Those records show whether aerial-ground cooperation survives more than a successful demonstration.
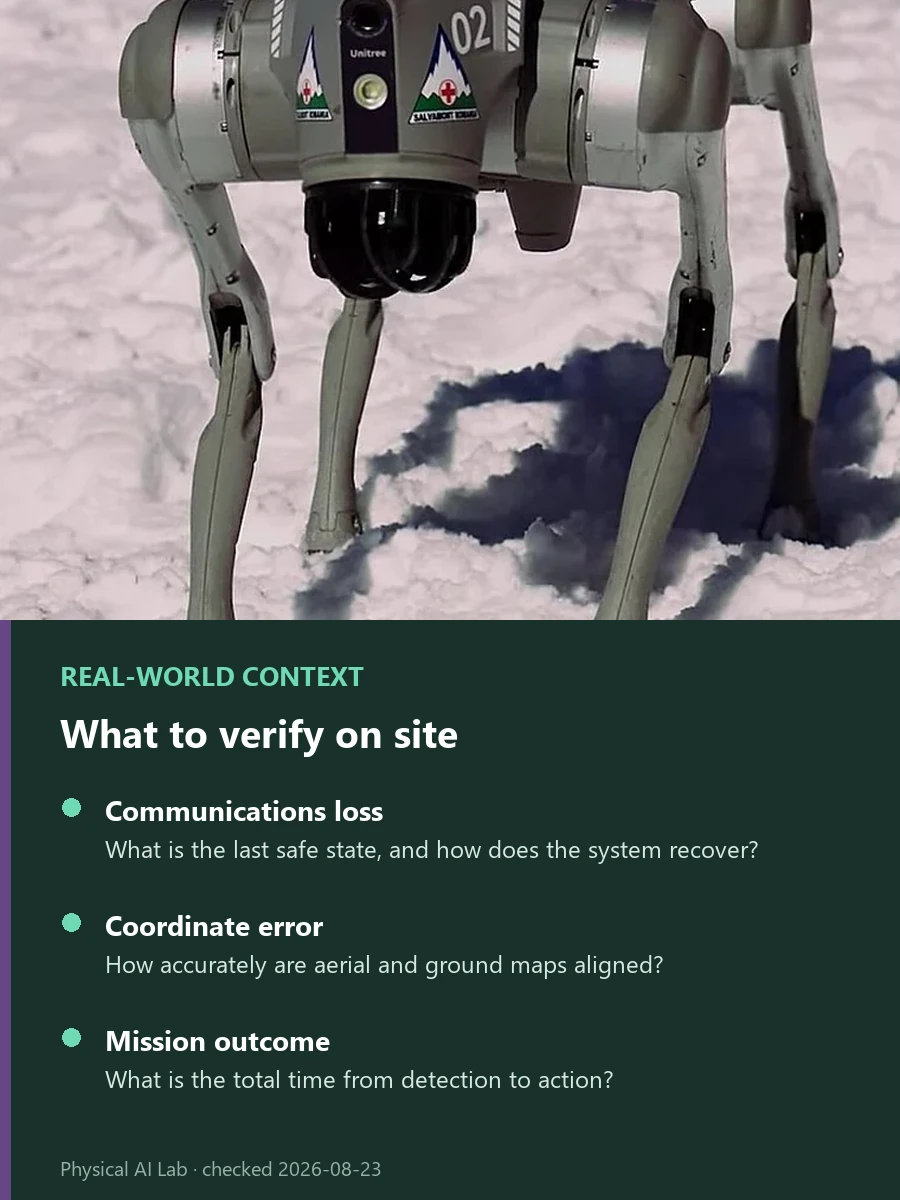
| Check | Question to ask |
|---|---|
| Communications loss | What is the last safe state, and how does the system recover? |
| Coordinate error | How accurately are aerial and ground maps aligned? |
| Mission outcome | What is the total time from detection to action? |

An indoor result does not generalize to a disaster site
Success in a clear indoor space cannot be assumed in wind, dust, GPS-denied areas or low light. The test plan should include communications loss and false detections.
Organizer and company material is the current primary evidence. Update the assessment when customer-site data, independent testing or regulatory documents become available.
Related tools for multi-robot operations
The warehouse picking robot guide supplies task-level metrics, Open-RMF multi-robot integration explains handoffs and VIO versus SLAM covers shared position estimates. This August 2026 analysis applies all three to an aerial-ground mission.
What would make aerial-ground collaboration deployable
The published WRC 2026 Tri-Co Robot Challenge design paired UAV reconnaissance with ground embodied intelligence in one task. The result that matters is repeatable detection-to-action performance under disclosed communication, mapping and recovery conditions—not the size of the announcement.
Frequently asked questions
What would make the Tri-Co challenge useful evidence for disaster-response deployment?
Publish the communication conditions, coordinate error, end-to-end detection-to-action time, human intervention and recovery after link loss. The ground task must finish safely; a successful aerial observation alone is incomplete evidence.
Which metric best captures UAV–ground robot coordination?
Measure total time from detection to action, then pair it with the human-intervention rate, mean recovery time, continuous operating time and failure conditions. Those four operating measures reveal what happens when the handoff breaks.
What should happen when the drone loses contact with the ground robot?
Each machine needs a defined last safe state, local fail-safe behavior, reconnection rule and mission-handoff record. The system should not depend on a continuous link to remain safe.
Official sources checked
- Beijing municipal government's official WRC 2026 event guide
- Invest Beijing's WRC 2026 industry overview
- World Robot Conference official service platform
Last checked: August 23, 2026