Skip to content

Physical AI Lab

  • Home
  • Physical AI
  • VLA Models
  • Sim-to-Real
  • Foundation Models
  • Humanoid Robots
  • 한국어
  • 日本語
  • 简体中文
  • 繁體中文

World Models and Simulation

English articles about world models and simulation at Physical AI Lab.

Isaac Lab-Arena policy regression testing: build a versioned evaluation gate

Published: September 27, 2026 by Physical AI Lab

Turn Isaac Lab-Arena Experiments, controlled variations and task metrics into a versioned policy regression gate without overstating simulation evidence.

Categories World Models and Simulation

Drake hydroelastic or point contact? Check the geometry pair first

Published: September 15, 2026 by Physical AI Lab

Drake can fall back to point contact even when a simulation runs. Check geometry representations, supported pairs and a version-specific documentation discrepancy.
Categories World Models and Simulation

Robot Simulator Comparison: Isaac Sim, MuJoCo and Gazebo by Engineering Workflow

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Isaac Sim, MuJoCo and Gazebo compared by robot engineering workflow

Compare Isaac Sim, MuJoCo and Gazebo for robot physics, sensors, rendering, learning, ROS integration, compute needs and validation.
Categories World Models and Simulation

Synthetic Data for Robot Learning: Labels, Randomization, Quality and Real-World Validation

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Synthetic robot data pipeline with scenes, labels, training and hardware validation

Learn synthetic data for robot learning, including labels, simulation, randomization, quality checks, real-data mixing and hardware validation.
Categories World Models and Simulation

World Models for Physical AI: State, Prediction, Planning and Robot Validation

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
World model predicting possible future robot states from actions

Learn how world models represent state, predict action outcomes, support robot planning and require uncertainty tracking and real-world validation.
Categories World Models and Simulation

Domain Randomization in Robotics: Variables, Ranges, Correlations and Real-World Validation

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Robot domain randomization across vision, physics, sensors and control

Learn domain randomization for robots across vision, physics, sensors and control, including range design, correlations and hardware validation.
Categories World Models and Simulation

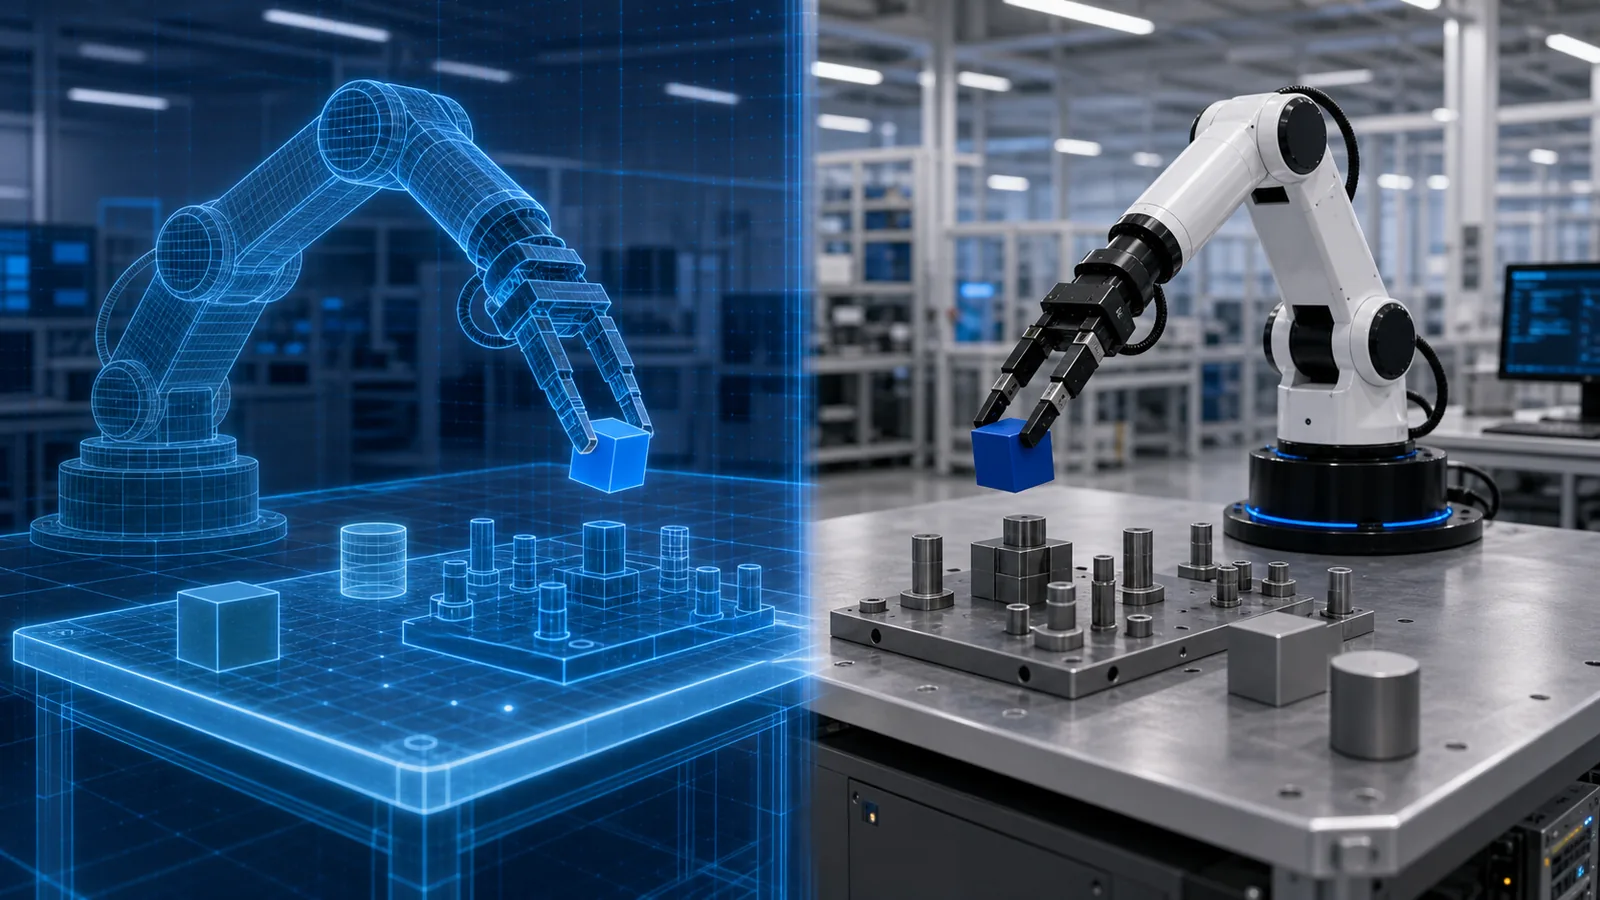
Why Sim-to-Real Fails: Five Reality Gaps and a Robot Debugging Workflow

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Five reality gaps that cause sim-to-real robot failures

Learn why sim-to-real robot transfer fails across vision, sensors, dynamics, control and task conditions, with a practical debugging workflow.
Categories World Models and Simulation

Sim-to-Real Transfer in Robotics: How Policies Cross the Reality Gap

Published: July 28, 2026 · Updated: October 12, 2026 by Physical AI Lab
Robot policy moving from a simulated environment to a physical robot

A practical guide to sim-to-real robotics: reality-gap causes, domain randomization, system identification, transfer methods and real-world validation.

Categories World Models and Simulation
Newer posts
← Previous Page1 … Page13 Page14

Explore Physical AI

  • Physical AI Fundamentals
  • Vision-Language-Action Models
  • Sim-to-Real Transfer
  • Robot Foundation Models
  • Humanoid Robots

View all English articles

About This Site

Physical AI Lab publishes independent, source-linked guides to embodied AI, robotics and real-world deployment.

Read the Korean edition · 日本語版を読む · 简体中文版 · 繁體中文版

© 2026 Physical AI Lab · English Edition · 한국어 · 日本語 · 简体中文 · 繁體中文