Skip to content

Physical AI Lab

  • Home
  • Physical AI
  • VLA Models
  • Sim-to-Real
  • Foundation Models
  • Humanoid Robots
  • 한국어
  • 日本語
  • 简体中文
  • 繁體中文

Physical AI Lab

Robot Actuator Structure: Motor, Transmission, Sensors, Drive, Bearings and Brake
Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Robot joint actuator structure from electrical input to mechanical output and feedback

Learn robot actuator structure from motor and transmission to encoders, torque sensing, drives, bearings, brakes, housing and thermal design.

Categories Robot Data and Hardware

Humanoid Robot Actuator Industry: Motors, Reducers, Sensors, Modules and Scale

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Humanoid robot actuator supply chain from components to joint modules

Map the humanoid robot actuator industry across motors, reducers, encoders, bearings, drives, joint modules, testing and manufacturing scale.
Categories Robot Data and Hardware

Robot Simulator Comparison: Isaac Sim, MuJoCo and Gazebo by Engineering Workflow

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Isaac Sim, MuJoCo and Gazebo compared by robot engineering workflow

Compare Isaac Sim, MuJoCo and Gazebo for robot physics, sensors, rendering, learning, ROS integration, compute needs and validation.

Categories World Models and Simulation

NVIDIA Isaac GR00T N1.7: Architecture, Data, Fine-Tuning and Robot Validation

Published: July 29, 2026 · Updated: September 23, 2026 by Physical AI Lab

Learn NVIDIA Isaac GR00T N1.7 architecture, data format, embodiment tags, fine-tuning, inference, evaluation and hardware validation.
Categories Robot Foundation Models

Physical AI Companies: How to Map the Robotics Ecosystem and Evaluate Evidence

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Physical AI company ecosystem across simulation, models, robots and deployment

Map Physical AI companies across simulation, data, models, robot hardware and deployment, with a practical framework for evaluating evidence.
Categories Physical AI Companies

Edge AI for Robots: Onboard Inference, Latency, Power, Safety and Cloud Roles

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Edge AI robot architecture connecting sensors, onboard inference, control and cloud services

Learn edge AI for robots, including onboard inference, latency, power, thermal limits, safety, updates and the right edge-cloud workload split.
Categories Robot Data and Hardware

Synthetic Data for Robot Learning: Labels, Randomization, Quality and Real-World Validation

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Synthetic robot data pipeline with scenes, labels, training and hardware validation

Learn synthetic data for robot learning, including labels, simulation, randomization, quality checks, real-data mixing and hardware validation.
Categories World Models and Simulation

Robot Sensors for Physical AI: Cameras, LiDAR, IMUs, Encoders, Force and Touch

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
Robot sensor suite including vision, range, motion, joint, force and touch

Compare robot cameras, depth, lidar, IMUs, encoders, force-torque and tactile sensors for Physical AI, fusion, calibration and safety.
Categories Robot Data and Hardware

World Models for Physical AI: State, Prediction, Planning and Robot Validation

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
World model predicting possible future robot states from actions

Learn how world models represent state, predict action outcomes, support robot planning and require uncertainty tracking and real-world validation.
Categories World Models and Simulation

The Physical AI See-Think-Act Loop: Perception, Decisions, Control and Feedback

Published: July 29, 2026 · Updated: August 1, 2026 by Physical AI Lab
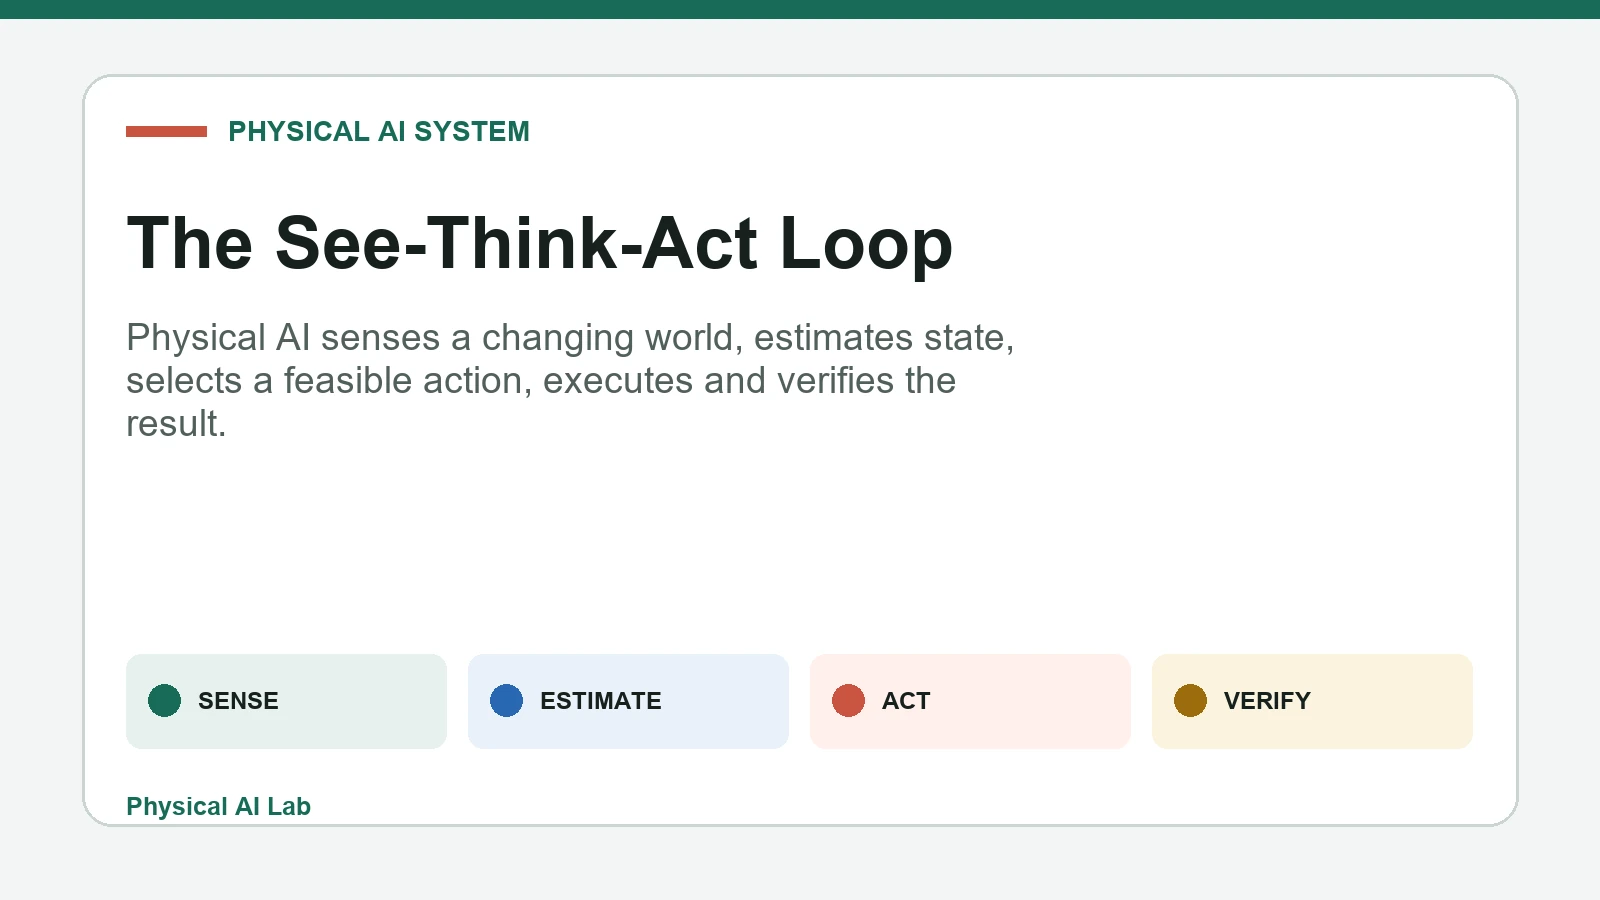
Physical AI loop connecting sensing, reasoning, action and feedback

Learn the Physical AI see-think-act loop, from robot sensing and state estimation to planning, control, feedback, safety and learning.

Categories Physical AI Fundamentals
Older posts
Newer posts
← Previous Page1 … Page45 Page46 Page47 Page48 Next →

Explore Physical AI

  • Physical AI Fundamentals
  • Vision-Language-Action Models
  • Sim-to-Real Transfer
  • Robot Foundation Models
  • Humanoid Robots

View all English articles

About This Site

Physical AI Lab publishes independent, source-linked guides to embodied AI, robotics and real-world deployment.

Read the Korean edition · 日本語版を読む · 简体中文版 · 繁體中文版

© 2026 Physical AI Lab · English Edition · 한국어 · 日本語 · 简体中文 · 繁體中文